
정의
htrans(posx1,posx2,ori_type_out)
기능
posx1과 posx2로부터 구한 Homogeneous Transformation matrix를 T1, T2라 할 때 T1*T2에 해당하는 자세를 리턴합니다.
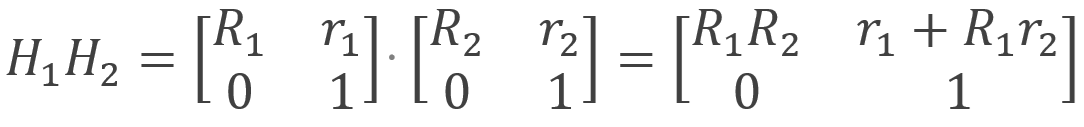
인수
|
인수명 |
자료형 |
기본값 |
설명 |
|---|---|---|---|
|
posx1 |
posx list (float[6]) |
- |
posx 또는 position list [mm, deg] |
|
posx2 |
posx list (float[6]) |
- |
posx 또는 position list [mm, deg] |
|
ori_type_out |
int |
None |
output orientation type
|
리턴
|
값 |
설명 |
|---|---|
|
posx |
[mm, deg] |
예외
|
예외 |
설명 |
|---|---|
|
DR_Error (DR_ERROR_TYPE) |
인수들의 데이터형 오류 시 |
예제
Python
posx1 = [100, 20, 300, 90, 0, 180]

posx2 = [200, 50, 100, 90, 30, 150]

posx = htrans(posx1,posx2)

posx_quat = htrans(posx1, posx2, DR_QUAT)