
Definition
get_current_rotm(ref)
Features
This function returns the direction and matrix of the current tool based on the ref coordinate.
Parameters
|
Parameter Name |
Data Type |
Default Value |
Description |
|---|---|---|---|
|
ref |
Int |
DR_BASE |
reference coordinate
|
Return
|
Value |
Description |
|---|---|
|
float[3][3] |
Rotation matrix |
Exception
|
Exception |
Description |
|---|---|
|
DR_Error (DR_ERROR_RUNTIME) |
C extension module error occurred |
Example
Python
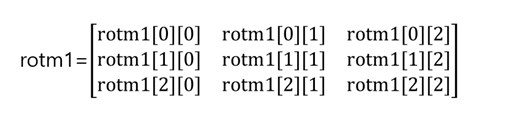
rotm1 = get_current_rotm(DR_WORLD) # rotm1 : rotation matrix(3x3) based on the world coordinate
# The result value is stored in a 3x3 matrix
Keyword
get / current / rotm / get_ / get_current