
Definition
htrans(posx1,posx2,ori_type_out)
Features
This function returns the pose corresponding to T1*T2 assuming that the homogeneous transformation matrices obtained from posx1 and posx2 are T1 and T2, respectively.
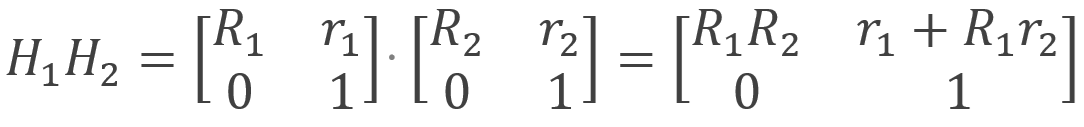
Parameters
|
Parameter Name |
Data Type |
Default Value |
Description |
|---|---|---|---|
|
posx1 |
posx list (float[6]) |
- |
posx or position list [mm, deg] |
|
posx2 |
posx list (float[6]) |
- |
posx or position list [mm, deg] |
|
ori_type_out |
int |
None |
output orientation type
|
Return
|
Value |
Description |
|---|---|
|
posx |
[mm, deg] |
Exception
|
Exception |
Description |
|---|---|
|
DR_Error (DR_ERROR_TYPE) |
Parameter data type error occurred |
Example
posx1 = [100, 20, 300, 90, 0, 180]
posx2 = [200, 50, 100, 90, 30, 150]
posx = htrans(posx1,posx2)
posx_quat = htrans(posx1, posx2, DR_QUAT)