
3.7.0 3.6.0 3.5.0 3.4.0 3.3.0 3.2.2 3.2.1 3.2.0 1. M/H Series 2. A Series 3. E Series 4. P Series Korean English Chinese Czech Dutch French German Hungarian Italian Japanese Polish Portuguese Spanish

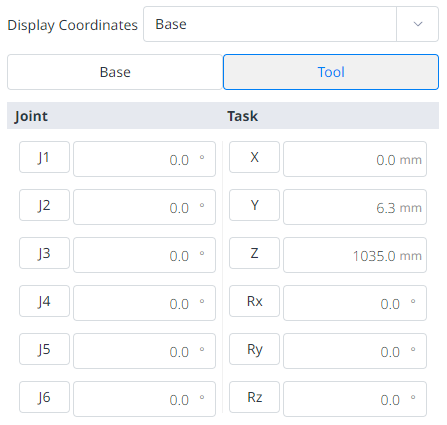
Setting Coordinates to Move Based on the Tool

image2023-4-28_11-4-54.png

To move the robot based on the tool coordinates, follow these steps:

  1. Select the Move tab and select the Task tab.

  2. Select the Tool tab.

  3. Configure the pose to move with reference to the tool.

  4. Tap and hold the Move to Corresponding Pose button to go to the set coordinates.