
This is a tool that tightens bolts.
-
If the tool supports reverse mode, it is possible to perform bolt removal tasks.
-
If the tool supports a vacuum function, it can receive bolts supplied from an external feeder.
-
If the tool has an auto-tightening torque check function, the successful tightening status is delivered via electrical signals.
-
If the tool is equipped with a sensor that checks input signals, input signal check is available.
-
It can be operated by the Controller / Flange Digital Output signals.
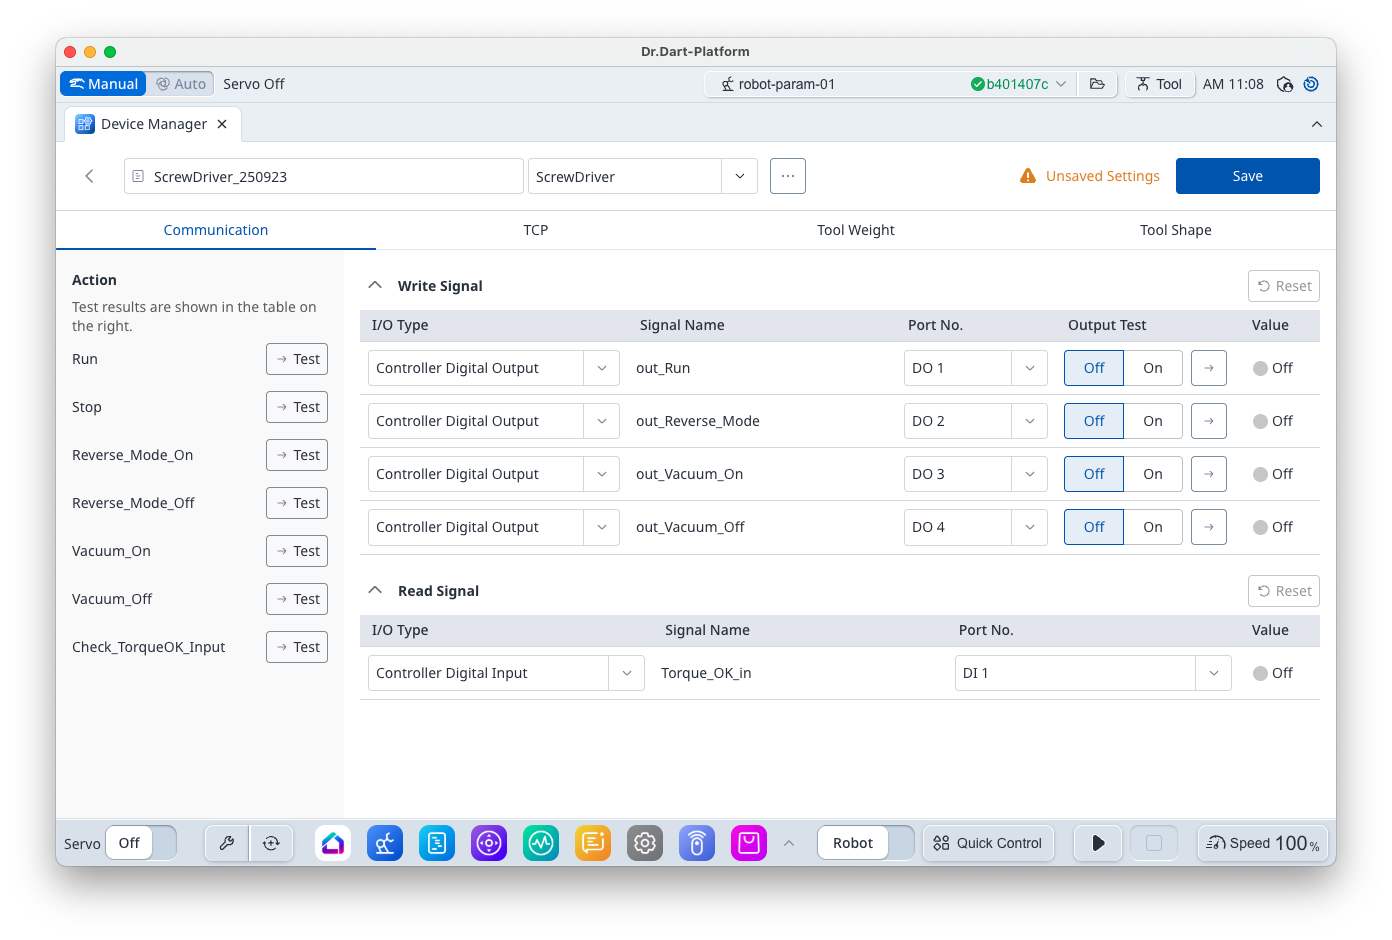
Signal Setting
|
Item |
Description |
|---|---|
|
out_Run |
This configures the signal that operates the screwdriver tool. The tool operates when a signal is received, and it does not operate when a signal is not received. |
|
out_Reverse_Mode |
This configures the reverse mode signal of tools that support reverse mode with external signals. |
|
out_Vacuum_On |
This configures the vacuum on signal to pick up a screw when a screw is supplied from an external feeder if a separate vacuum tool is installed. |
|
out_Vacuum_Off |
This configures the vacuum off signal to pick up a screw when a screw is supplied from an external feeder if a separate vacuum tool is installed. |
|
Torque_OK_in |
This configures the input signal of the tightening torque OK status if the tool has an auto tightening torque check function. |
Support Action (DRL)
|
Item |
Description |
|---|---|
|
Run |
[Mandatory Action] It operates the tool with out_Run signal on. |
|
Stop |
[Mandatory Action] It stops the tool with out_Run signal off. |
|
Reverse_Mode_On |
It enables reverse mode with the out_Reverse_Mode signal on. |
|
Reverse_Mode_Off |
It disables reverse mode with the out_Reverse_Mode signal off. |
|
Vacuum_On |
It operates the vaccum with the out_Vacuum_On signal on and the out_Vacuum_Off signal off. |
|
Vacuum_Off |
It stops the vaccum with the out_Vacuum_On signal off and the out_Vacuum_Off signal on. |
|
Check_TorqueOK_Input |
It waits for an input signal related to reaching the target torque (end task). (Timeout = 10 seconds) |