This example handles workpieces continuously supplied by one conveyor. If a workpiece is handled between [Conveyor Tracking] and [End Conveyor Tracking], and if the overall work time is not sufficient, obtain [Conveyor Coordinates] information rather than performing [End Conveyor Tracking] to continue the work.
If tracking has to be ended for each workpiece, place [Conveyor Coordinates] and [Conveyor Tracking] after [End Conveyor Tracking]. If the coordinates of the next workpiece are obtained before the deceleration finishes, the robot moves on to tracking the next workpiece from its current speed without waiting for the deceleration to finish.
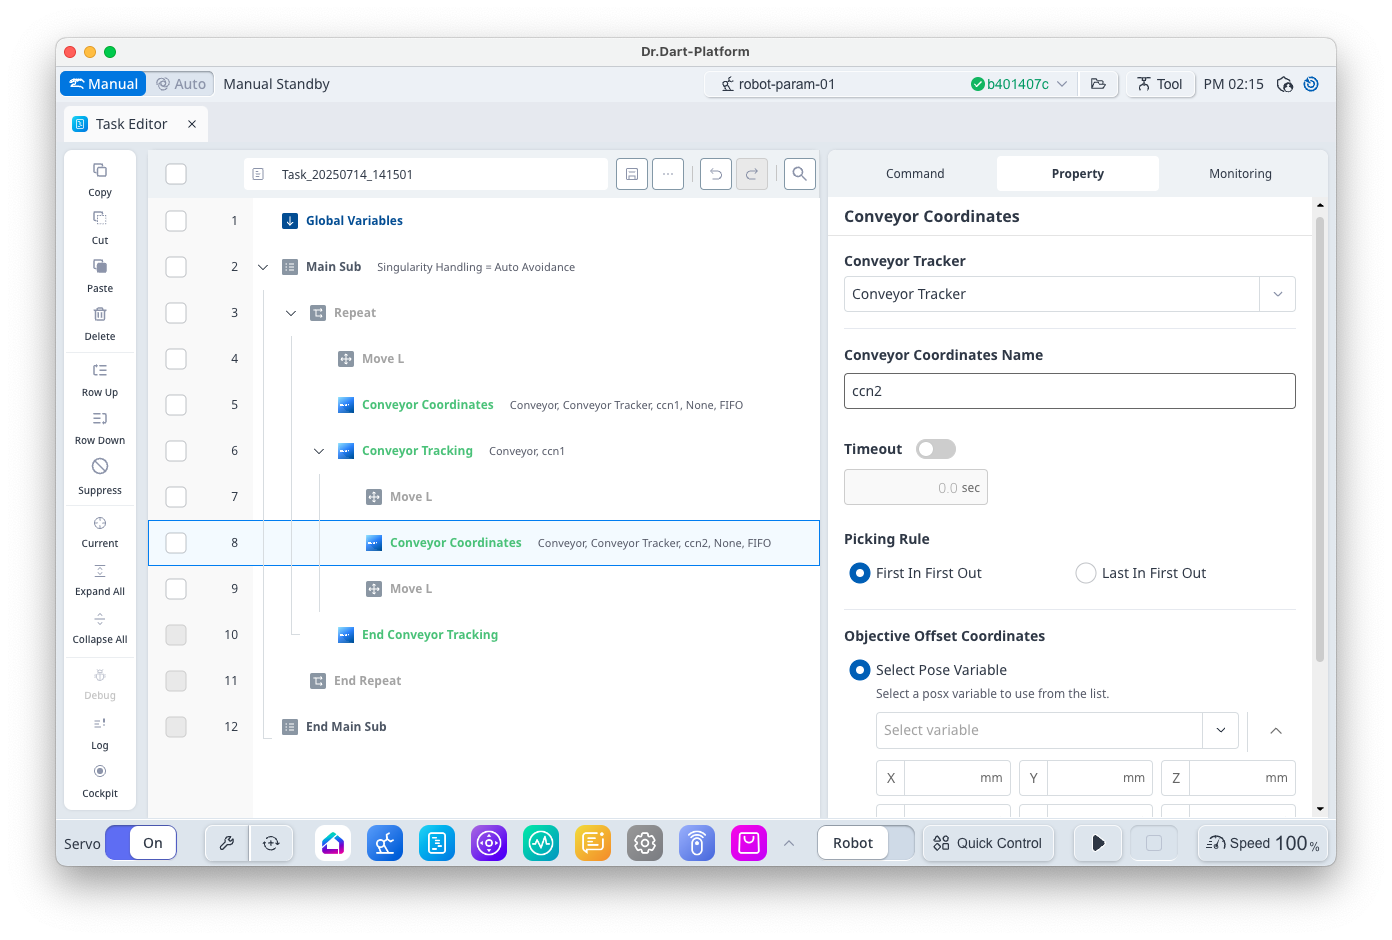
Note that it is necessary to differentiate the first coordinates and the second coordinates when teaching. Select coordinates suited for the workpiece, perform Start Teaching, and perform Get Pose to obtain teaching points suited for each coordinate. If the workpiece is identical, it is acceptable to share identical teaching points.