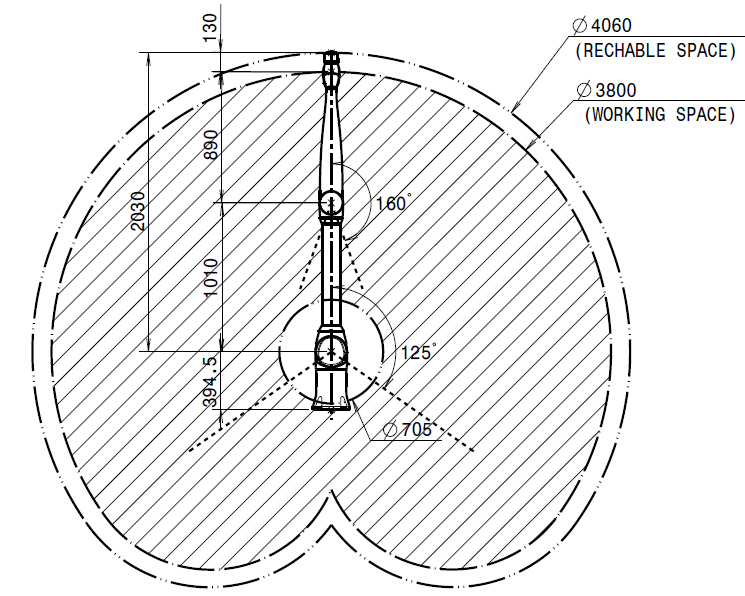
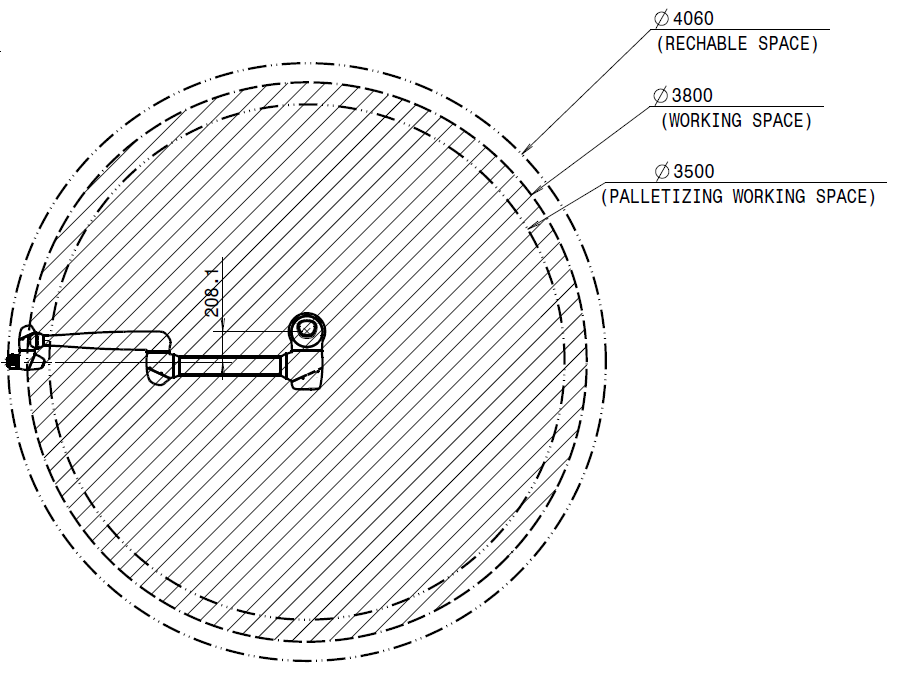
Robot operating space
P3020
|
|
|---|
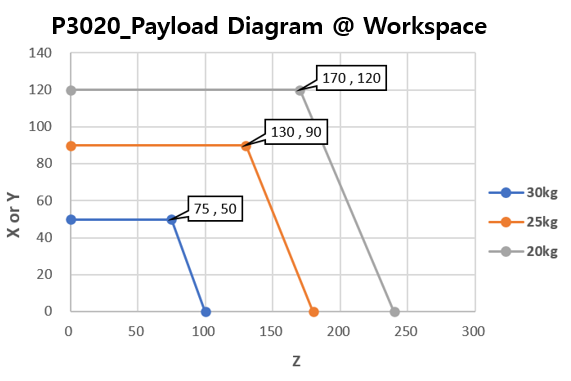
Max. Payload within operating space
The maximum payload of the robot within its operating space changes according to the distance from the center of gravity. Payload per distance is as follows:
Note
This load diagram assumes a small tool load volume. Tools with a larger volume will have greater limitations in payload above the tool’s center of gravity compared to a tool with an equal weight but smaller volume, and in such cases, vibration may occur.
P3020
Allowed Moment and Inertia
The allowed moment and inertia for the J4-J6 robot are as follows:
|
Model Name
|
J4 |
J5 |
J6 |
|||
|---|---|---|---|---|---|---|
|
Allowed Moment |
Inertia |
Allowed Moment |
Inertia |
Allowed Moment |
Inertia |
|
|
P3020 |
- |
- |
55 Nm |
3.1 kg㎡ |
36 Nm |
2.0 kg㎡ |
Note
-
For P3020, the tilt (J5) angle is limited based on the tool weight and center of gravity set in Tool Weight, so that the moment applied to J5 when the tool is tilted does not exceed the allowed moment of J5.
-
The limited range is around the posture where the tool is close to horizontal (where the center of gravity of the tool is farthest from the J5 axis). If the tool is light or its center of gravity is close to the J5 axis, the limit is not applied.
-
If the robot enters the limited range during motion, it stops with Stop Category 1. For the travel distance during stopping, refer to the P3020 Stop Category page.
-
The payload diagram is based on the tool-down posture. The tilt angle limit may be applied even to a tool within the range of the diagram.
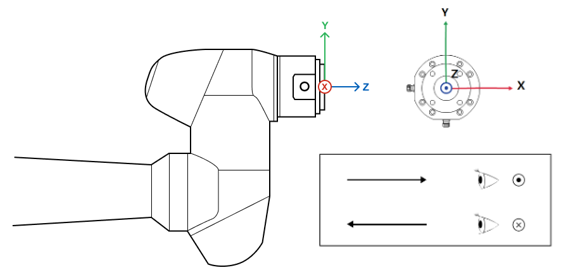
Tool Center Point (TCP)
Refer to the figure below for TCP.
Basic specifications
|
Model Name |
P3020 |
|---|---|
|
Weight |
83 kg |
|
Payload within Work Radius |
30 kg |
|
Max. Work Radius |
1900 mm |
|
Number of Axes |
5 |
|
Max. TCP Speed |
Over 1 m/s |
|
Position Repeatability (ISO 9283) |
±0.1 mm |
|
Protection Rating |
IP 54 |
|
Noise |
< 65 dB |
|
Installation Direction |
Floor Only |
|
Controller and Teaching Pendant |
Doosan Controller & Teach Pendant |
|
Vibration and Acceleration |
10≤f<57㎐ - 0.075mm amplitude 57≤f≤150㎐ – 1G |
|
Impact |
Max Amplitude : 50㎨(5G)
|
|
Operating Temperature |
0 ℃ ~45 ℃ (273K to 318K) |
|
Storage Temperature |
-5 ℃ ~50 ℃ (268K to 323K) |
|
Humidity |
20% ~ 80% |
Axis Specifications
|
Model Name |
P3020 |
|---|---|
|
Operating Angle |
|
|
J1 |
±360° (TP:±360°) |
|
J2 |
±125° (TP:±95°) |
|
J3 |
±160° (TP:±135°) |
|
J4 |
- |
|
J5 |
±360° (TP:±135°) |
|
J6 |
±360° (TP:±360°) |
|
Max. Speed per Axis (rated payload operation) |
|
|
J1 |
100 °/s |
|
J2 |
80 °/s |
|
J3 |
80 °/s |
|
J4 |
- |
|
J5 |
200 °/s |
|
J6 |
360 °/s |