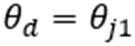3.7.0 3.6.0 3.5.0 3.4.0 3.3.0 3.2.2 3.2.1 3.2.0 1. M/H Series 2. A Series 3. E Series 4. P Series Korean English Chinese Czech Dutch French German Hungarian Italian Japanese Polish Portuguese Spanish

Measurement Poses and Conditions

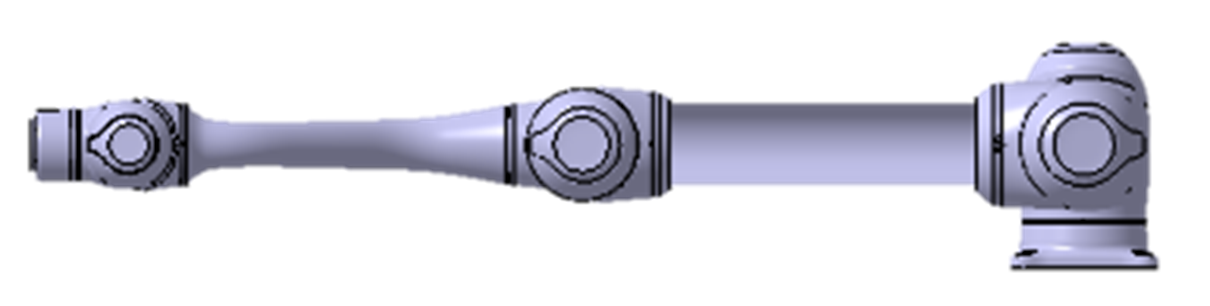
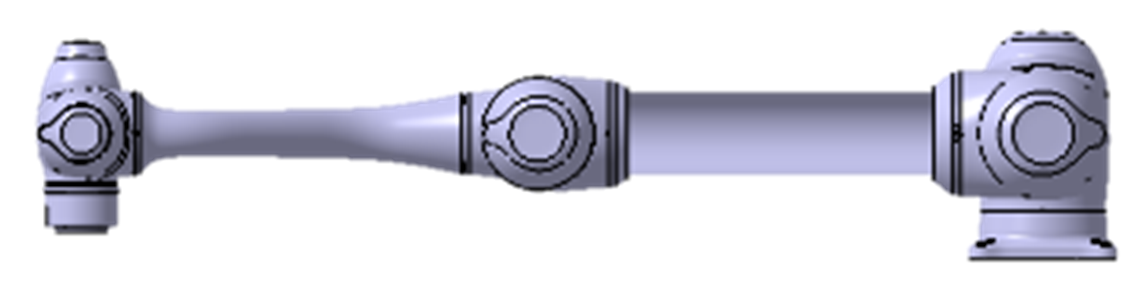
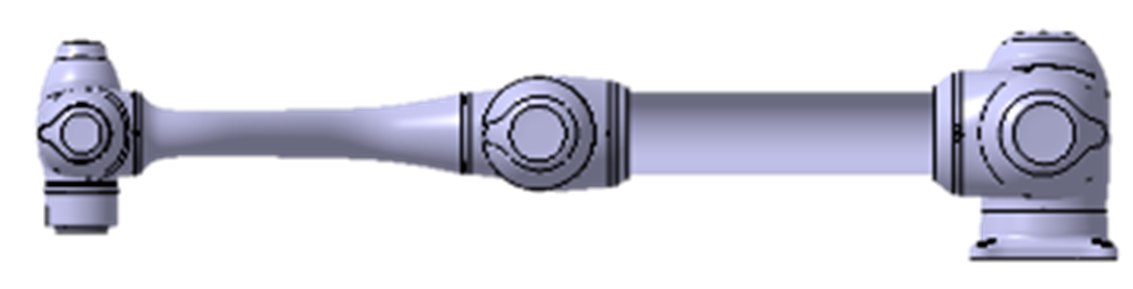
Joint 1 measurement is performed with the rotating axis perpendicular to the ground and during horizontal movement.

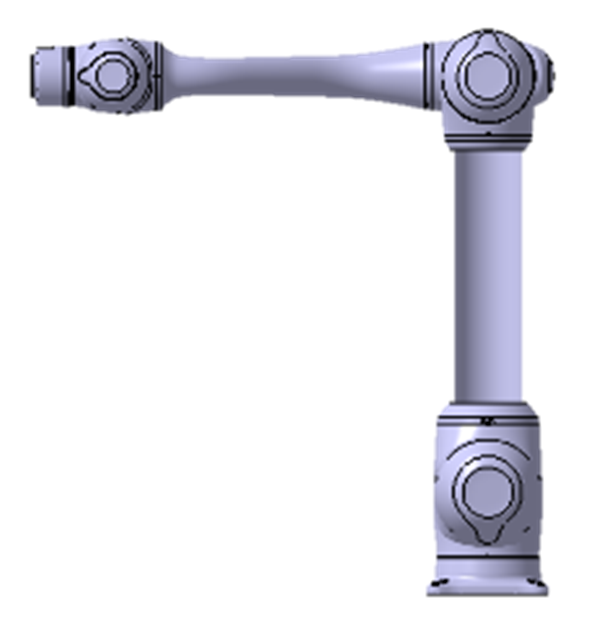
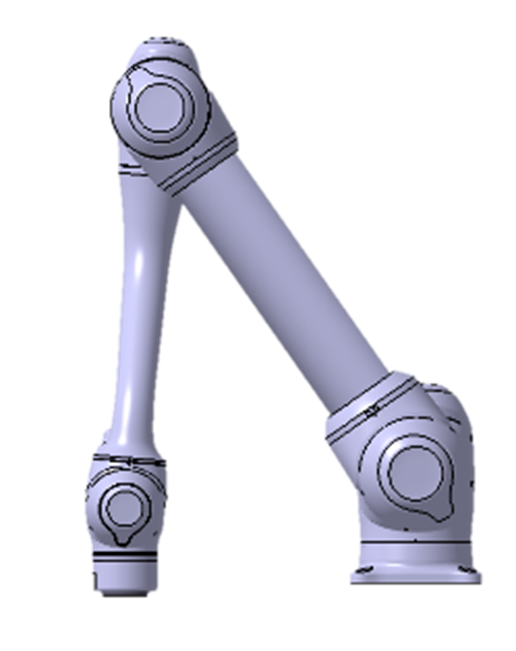
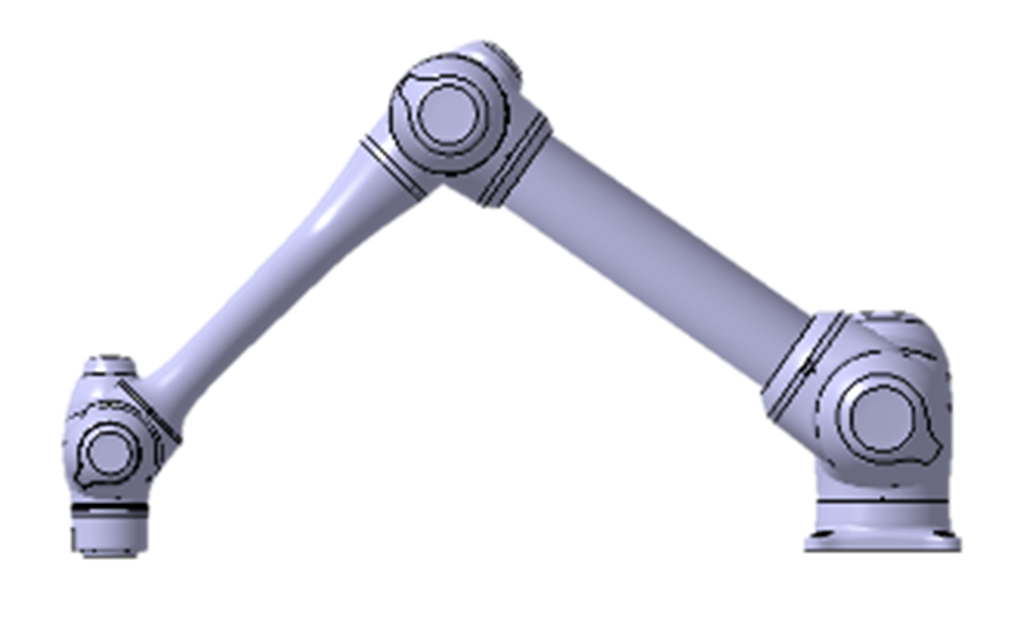
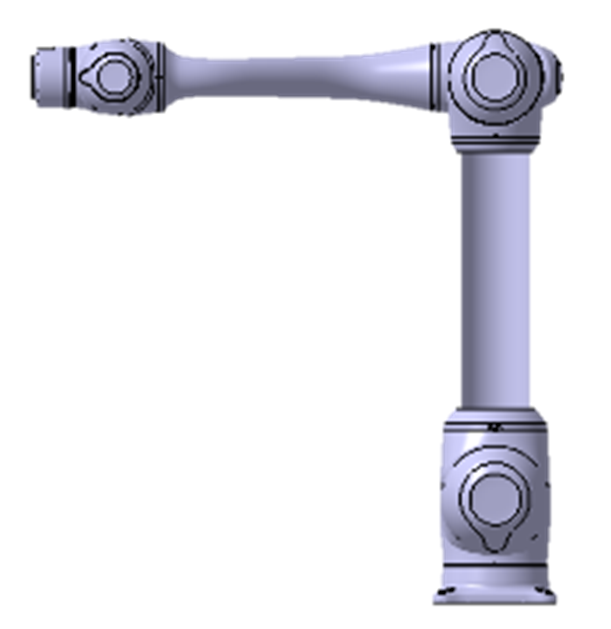
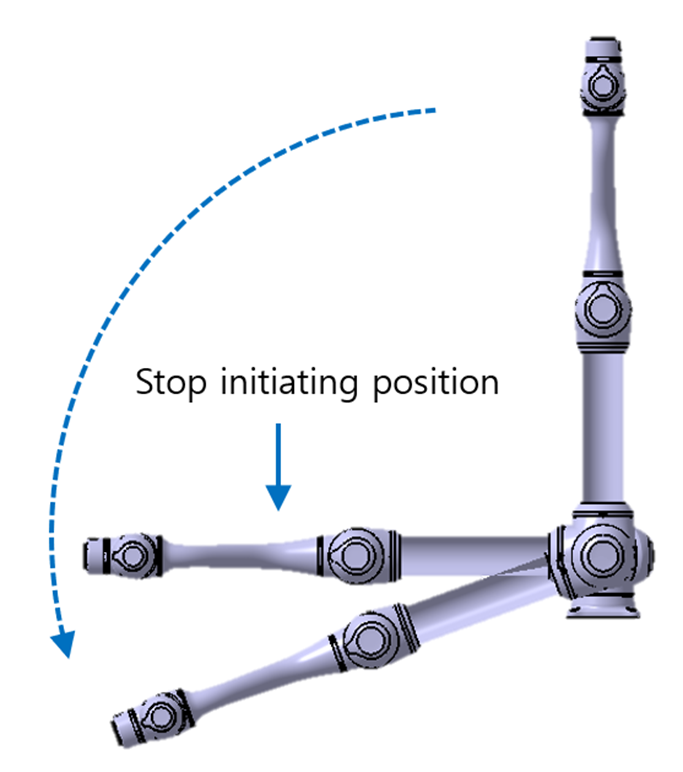
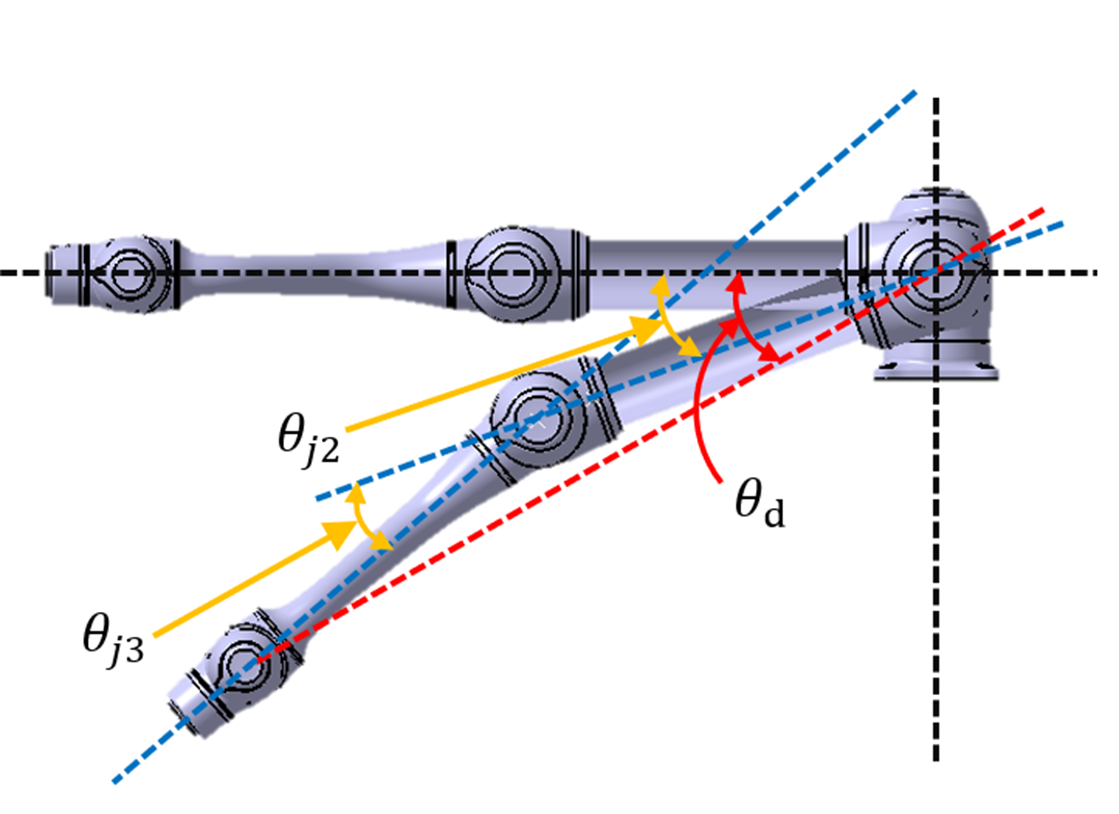
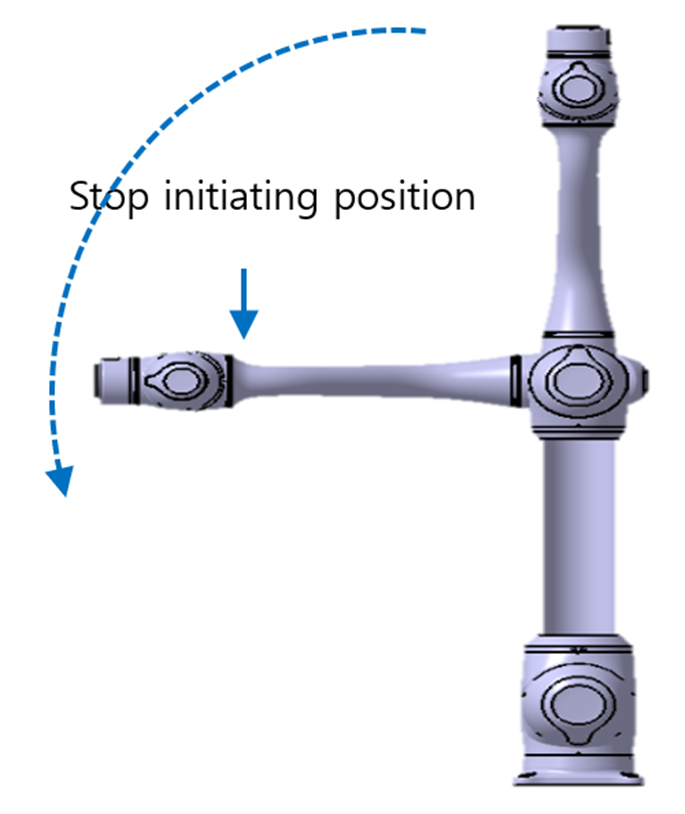
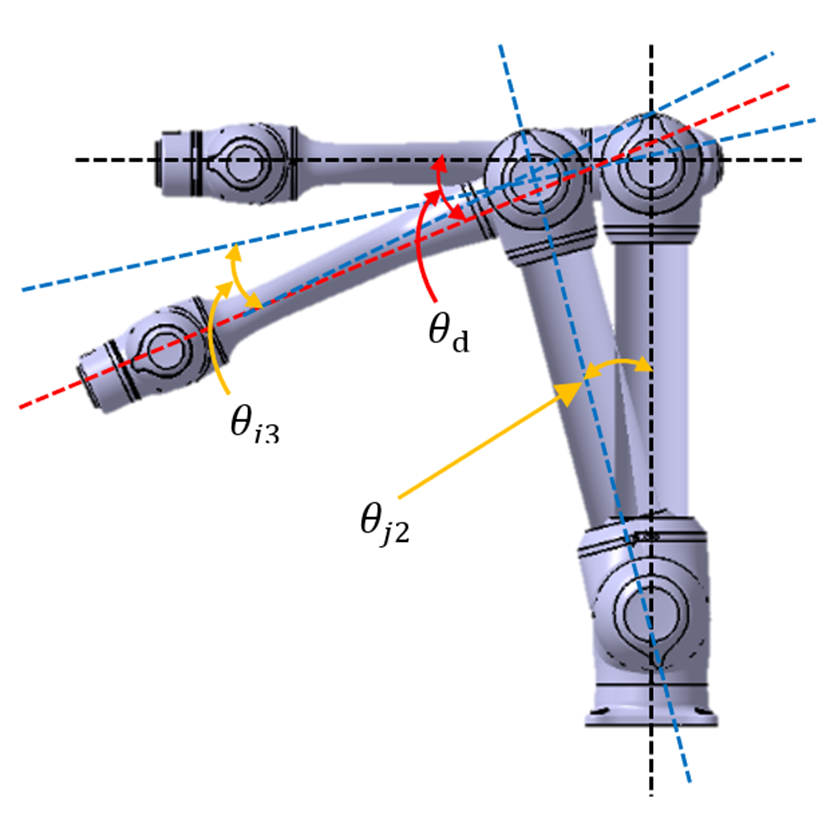
Joint 2 and Joint 3 measurements are performed with the rotating axis parallel to the ground and when the robot is stopped in a downward movement vertical to the ground.

Note

The measurements are the result of the worst case. Measurement may vary according to circumstances

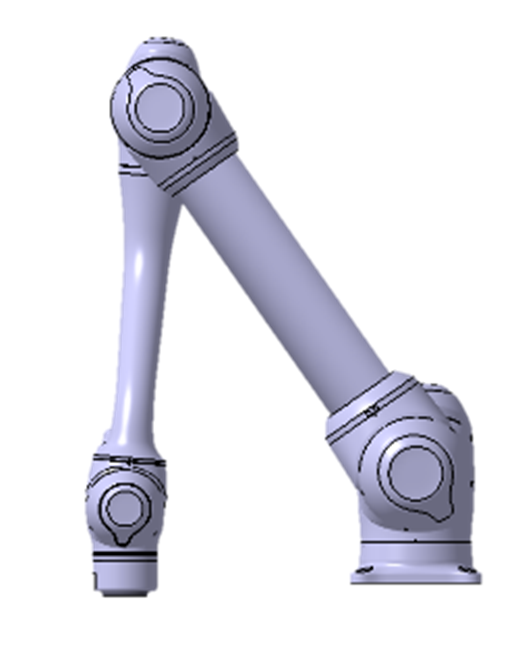
The pose for 33%, 66%, and 100% of extension


Joint 1

Joint 2

Joint 3

100% extension

Stop category 0

  image2021-11-15_10-51-46.png

  image2021-11-15_10-52-29.png

  image2021-11-15_10-53-9.png

33% extension

Stop category 1

  image2021-11-15_10-54-0.png

  image2021-11-15_10-54-41.png


-

66% extension

Stop category 1

  image2021-11-15_10-55-12.png

  image2021-11-15_10-55-40.png


-

100% extension

Stop category 1

  image2021-11-15_10-56-20.png

  image2021-11-15_10-56-51.png

  image2021-11-15_10-57-20.png

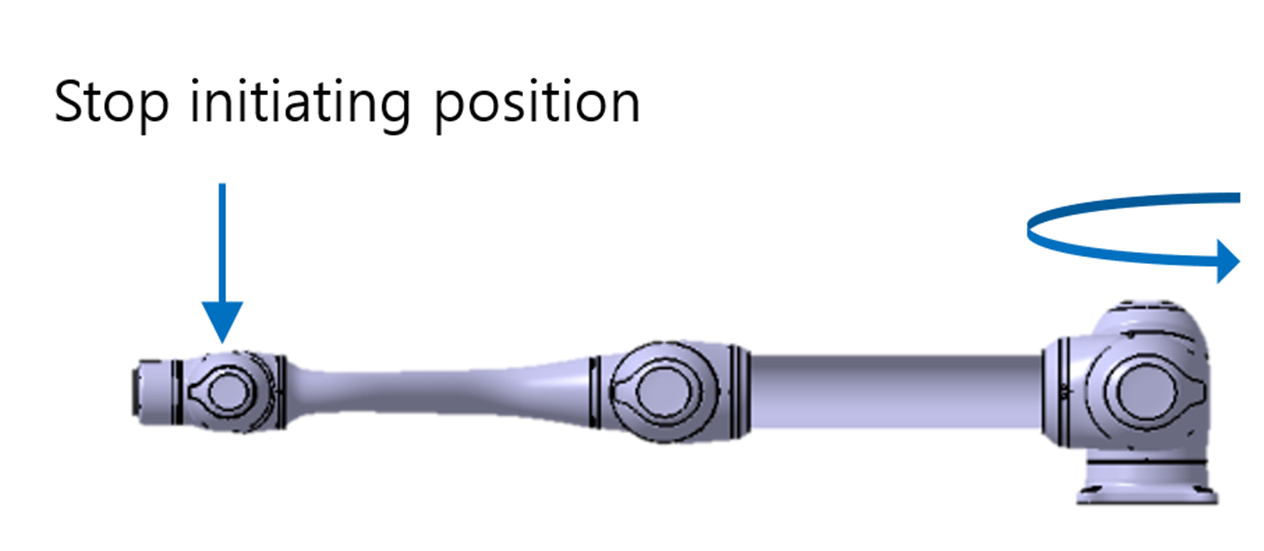
The pose when the stop is initiated and the measured angle ( image2021-11-15_11-41-21.png )


Joint 1

Joint 2

Joint1


  image2021-11-15_11-13-53.png

 No slip,   image2021-11-15_11-8-31.png

Joint2

  image2021-11-15_11-14-51.png

  image2021-11-15_11-16-1.png

Joint3

  image2021-11-15_11-17-6.png

  image2021-11-15_11-18-5.png