
Definition
tracking_conveyor(conv_id, time=0.3)
Features
The robot starts Conveyor Tracking.
Parameters
|
Parameter Name |
Data Type |
Default Value |
Description |
|---|---|---|---|
|
conv_id |
int |
- |
Conveyor ID |
|
time |
float |
0.3 |
Acceleration time(sec) to start Tracking |
Note
If the tracking_conveyor command is given, the conveyor starts tracking from the current position of robot. You can call task motion right after tracking_conveyor function for reducing tack time, although transient error can occur during acceleration time.
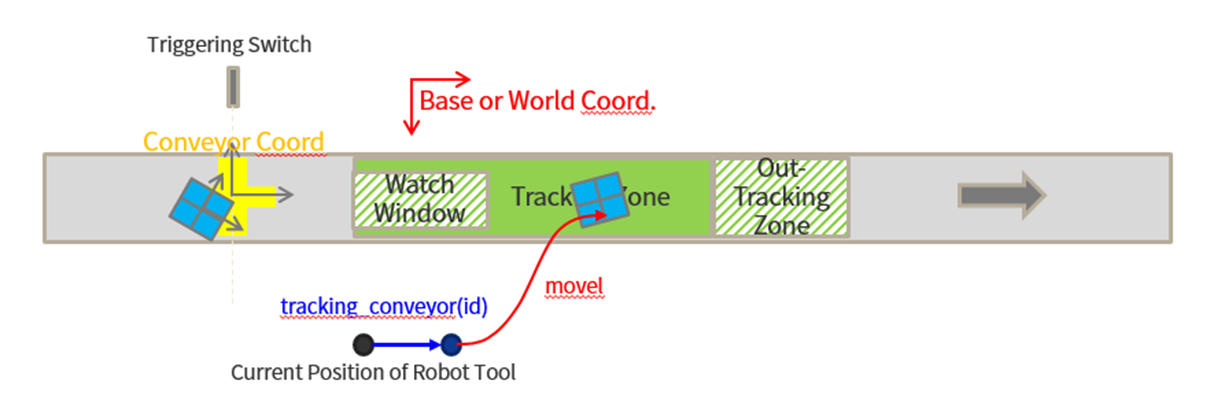
[tracking sequence]
Return
|
Value |
Description |
|---|---|
|
0 |
Conveyor Tracking success |
|
Negative integer |
If the robot is expected to exit the robot work space during acceleration |
Exception
|
Exception |
Description |
|---|---|
|
DR_Error (DR_ERROR_TYPE) |
Parameter data error occurred |
|
DR_Error (DR_ERROR_VALUE) |
Parameter value is invalid |
|
DR_Error (DR_ERROR_RUNTIME) |
C Extension module error occurred |
|
DR_Error (DR_ERROR_STOP) |
Program terminated forcefully |
Example
CONV1 = set_conveyor(‘conveyor1’)

while True:
CONV_COORD_1 = get_conveyor_obj(CONV1)

tracking_conveyor(CONV1) # start moving to track conveyor

# task on conveyor
movel(posx(0,0, 50, 0, 0, 0), ref=CONV_COORD_1)
movel(posx(0,0, 0, 0, 0, 0), ref=CONV_COORD_1)
set_digital_output(DO_GRIPPER, 1)
movel(posx(0,0, 50, 0, 0, 0), ref=CONV_COORD_1)

untracking_conveyor(CONV1)
obj_count = obj_count + 1
Related commands
Keyword
tracking / conveyor